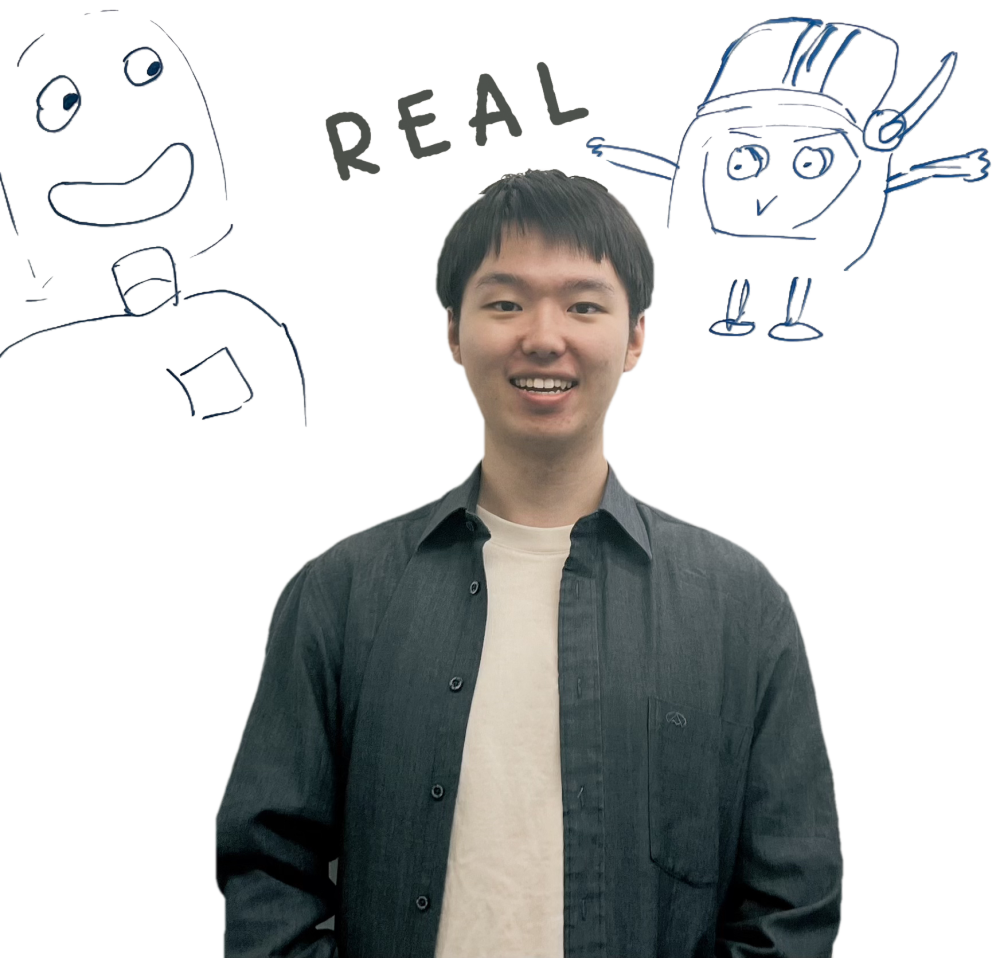
I am a second-year PhD student in Mechanical Engineering at the University of California, Riverside, advised by Prof. Mingyu Cai in the REAL Lab. Before that I received my M.S. in Computer Science from the University of Virginia (advised by Prof. Shangtong Zhang) and my B.Eng. in Electronic Information Engineering from Huazhong University of Science and Technology (advised by Prof. Xin Yang).
My research sits at the intersection of robot learning, formal methods, and motion planning. I am especially interested in making symbolic specifications, in particular spatio-temporal logic, differentiable, so that geometric and temporal task structure can be plugged directly into reinforcement learning, imitation learning, and policy evaluation pipelines.
CV ↗ · Google Scholar ↗ · GitHub ↗
Research interests
- Differentiable spatio-temporal logic for robot manipulation
- Reinforcement learning and imitation learning with symbolic structure
- Motion planning under uncertainty (conformal prediction, dynamic environments)
- Multi-robot navigation and hybrid RL–planning frameworks
- Natural language to formal task specification (NL2SpaTiaL)
News
-
Two papers accepted to IROS 2026
Differentiable SpaTiaL and NL2SpaTiaL will appear at IROS 2026. We are building SpaTiaL into a general foundation for robots that understand, ground, and act on human intent, from natural language to spatio-temporal structure to motion. See you in Pittsburgh!
-
Oral talk at L4DC 2026
Time-aware Motion Planning with Conformal Prediction was selected for an oral presentation at L4DC 2026 in Los Angeles.
-
Next round of SpaTiaL work
Cooking up the next round of Differentiable SpaTiaL and NL2SpaTiaL: robots that understand spatio-temporal goals from natural language. Stay tuned.
-
Started my PhD at UC Riverside
Officially joined the REAL Lab with Prof. Mingyu Cai. Loving the desert sun and the robots.
-
Wrapped up my M.S. at UVA
Master’s thesis on Policy Optimization in Robust MDPs. Onward!
Selected publications
-
Differentiable SpaTiaL: Symbolic Learning and Reasoning with Geometric Temporal Logic for Manipulation Tasks
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
-
NL2SpaTiaL: Generating Geometric Spatio-Temporal Logic Specifications from Natural Language for Manipulation Tasks
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
-
Time-aware Motion Planning in Dynamic Environments with Conformal Prediction
Learning for Dynamics and Control (L4DC) · Oral
-
Bridging Deep Reinforcement Learning and Motion Planning for Model-Free Navigation in Cluttered Environments
arXiv preprint
See the full list.
Education
- Jan 2025 – presentPh.D. in Mechanical Engineering, University of California, Riverside
- Aug 2023 – Dec 2024M.S. in Computer Science, University of Virginia
- Sep 2019 – Jun 2023B.Eng. in Electronic Information Engineering, Huazhong University of Science and Technology (graduated with honors)
Contact
- academic emaillichengl [at] ucr.edu
- personal emaillichengluo2001 [at] gmail.com
- locationRiverside, CA